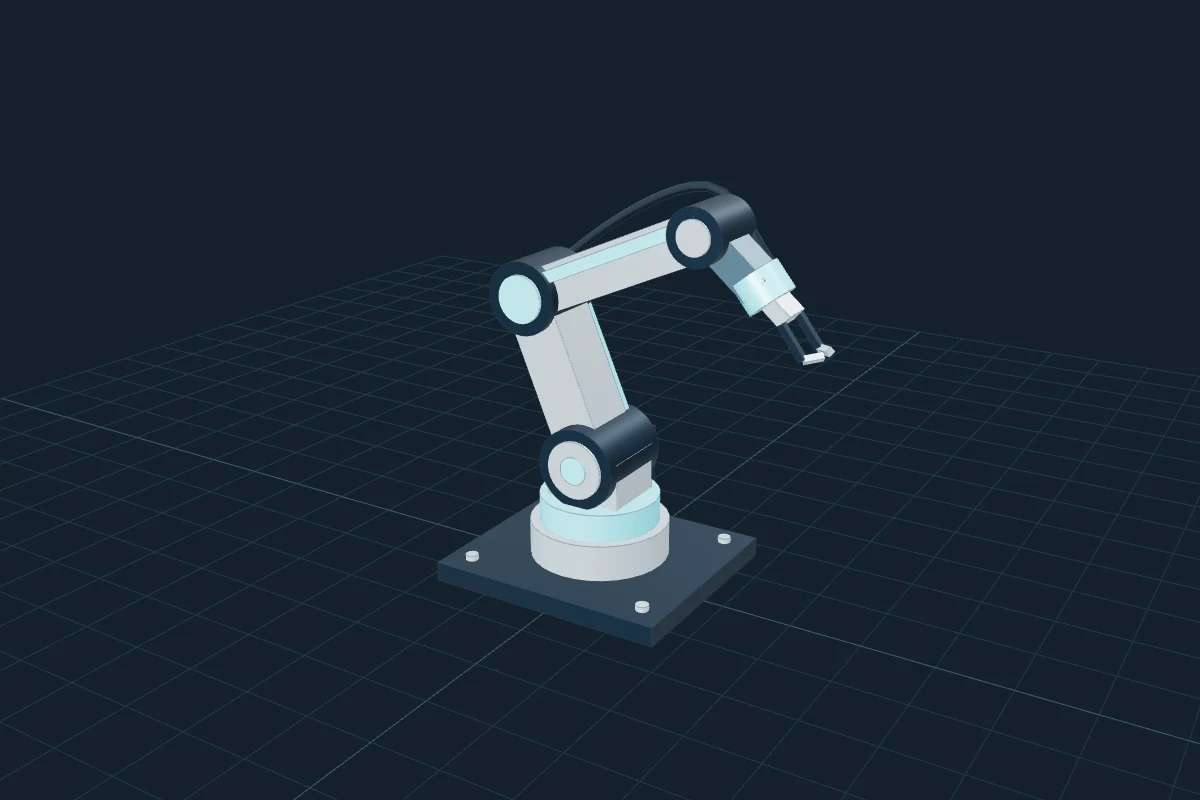
An articulated robot concept exploring joint architecture, reach and end-effector integration.
CONCEPT STUDY / NOT A CLIENT PROJECT
Design intent
Explore the mechanical architecture of an articulated arm for industrial handling and automation.
Scope & deliverables
Base and shoulder joints, upper/lower arm links, wrist packaging, cable routing and gripper interface. This is an illustrative concept; replace with approved project specifications and verified outcomes.
Tools & industry
3D CAD concept modeling / Industrial automation
Engineering notes
The supplied visual is a lightweight demonstrator. It has not been analysed, manufactured or certified for operational use.